Robotics
Robot learning, humanoids, manipulation, ROS and autonomous systems. 342 videos, ordered by views. Open the playlist in Frontier Concepts or watch it in TV mode.
Do You Love Me?
Our whole crew got together to celebrate the start of what we hope will be a happier year: Happy New Year from all of us at Boston Dynamics. www.BostonDynamics.com.…

Introducing WildCat
WildCat is a four-legged robot being developed to run fast on all types of terrain. So far WildCat has run at about 19 mph on flat terrain using bounding and galloping gaits. The v…
This Unstoppable Robot Could Save Your Life
This robot has applications to archaeology, space exploration, and search and rescue — with a simple elegant design inspired by a plant. Sign up to Morning Brew for free today: htt…

Why Is MIT Making Robot Insects?
What happens when you shrink robots down to the size of insects? Let’s explore the mind-bending physics behind their superpowers! Engineers get Onshape Professional free up to 6 mo…

BigDog Overview (Updated March 2010)
BigDog climbs in the woods, keeps its balance when kicked and when slipping on ice, travels through snow and mud, jogs 5 mph, and climbs some rubble.…

I made a hair cutting machine
My hair is getting too long so I decided to build a robot to cut it for me. To support future projects like this check out my patreon: http://patreon.com/stuffmadehere Check out th…

How many robots does it take to run a grocery store?
In Ocado's grocery warehouses, thousands of mechanical boxes move on the Hive. Are they all individual robots? Or is this one giant hive mind? • Thanks to Ocado: https://www.ocadog…

Gemini Robotics 2 brings whole body intelligence to robots
For decades, we’ve dreamed of robots that can seamlessly step into our world and lend a hand. Now, that vision takes a significant stride forward. Most robots are pre-programmed or…
How NVIDIA's Jensen Huang Wants to be Remembered
What NVIDIA is trying to build next… Subscribe for more optimistic science and tech stories from our show Huge If True. You're probably hearing a lot about AI, DeepSeek, NVIDIA and…

ACTROID-F in AIST Open Lab 2010 02
産総研オープンラボ2010で紹介されていた、アクトロイド-Fの動作の様子のその2。アクトロイド-Fを操作する様子などを紹介。ロボタイムズ(http://robo-times.com/)…

What’s Next in Robotics?
By combining decades of real-world data with advanced AI, simulation and digital twins, teams are rapidly training, validating, and deploying intelligent robotics at scale. Physica…

Who cares about topology? (Old version)
There’s now an updated version: https://youtu.be/IQqtsm-bBRU…

Lecture 1 | Machine Learning (Stanford)
Lecture by Professor Andrew Ng for Machine Learning (CS 229) in the Stanford Computer Science department. Professor Ng provides an overview of the course in this introductory meeti…

New Hands for Atlas | Boston Dynamics
This new generation hand is the perfect companion for Atlas. With 13 degrees of freedom, these hands are directly actuated, built for high fidelity simulation to enable sim-to-real…

Inside the Lab: Taking Atlas From Sim to Scaffold
How does Atlas recognize and interact with objects? How do we develop new Atlas behaviors? Why is manipulation important for the future of robotics? Join our team in the Atlas lab …

Cassie - Next Generation Robot
Engineers at Oregon State University are creating the next generation of bipedal robots. To find out more: http://mime.oregonstate.edu/. ———————————— We do social media: Facebook: …

Robots that fly ... and cooperate | Vijay Kumar
http://www.ted.com In his lab at Penn, Vijay Kumar and his team build flying quadrotors, small, agile robots that swarm, sense each other, and form ad hoc teams -- for construction…

Inside the lab: How does Atlas work?
Go behind the scenes at Boston Dynamics with the Atlas Team as we work to train multiple Atlas robots to maneuver their way through our most complex parkour course yet. The team pu…

How Boston Dynamics' Spot Robot Works!
Adam Savage has been operating Boston Dynamics' Spot robot for a few months, getting to know the ins and outs of its capabilities. While more projects with Spot are in the works, A…
Nvidia Microduck AI Robots are mind blowing - World Premiere and First Look
Have a look at the new Nvidia Microduck AI robots. NVIDIA CEO Jensen Huang was joined onstage at GTC Berlin 2026 by four waddling Microduck robots. Developed by Hugging Face and Fr…

DIY AI Lockpicking Robot: ESP32 + Claude AI Opens Any Lock!
I built an ESP32 and AI-powered lockpicking machine capable of opening locks automatically. The entire frame and mechanics are 3D printed, built using accessible electronics compon…

NEO The Home Robot | Order Today
NEO is a safe humanoid robot that does your chores and offers personalized assistance. Order now: https://1x.tech/neo Connect with 1X: Website: https://1x.tech X: https://x.com/1x_…

Unitree demostration during the Chinese New Year Gala is incredible!
Learn how to program humanoids like that here: https://www.theconstruct.ai/humanoid-robot-reinforcement-learning-training/ Check out Unitree’s humanoid robots at the 2026 CCTV Spri…

Pick, Carry, Place, Repeat | Inside the Lab with Atlas
Last year, we unveiled the new Atlas—faster, stronger, more compact, and less messy. We’re designing the world’s most dynamic humanoid robot to do anything and everything, but we g…

An actual, real-world use for robot dogs
At a pumped storage plant in western Austria, a company called Energy Robotics is testing robot dogs for inspection. All the fancy Boston Dynamics publicity stunts aside: are the r…

I spent 3 days at MIT... the robot hype is worse than you think
Omnigent is an open source meta-harness to run all your AI agents in one place. Try it free - https://bit.ly/4fXzeo8 I spent last week at MIT's CSAIL lab learning where the frontie…

Robotics Expert Breaks Down Robot Scenes From Film & TV | WIRED
Chris Atkeson, a professor at the Robotics Institute at Carnegie Mellon University, watches a variety of scenes featuring robots from movies and television and breaks down how accu…

Air Hockey Robot Project (a 3D printer hack) by JJROBOTS
This project is now hosted on our new website: http://jjrobots.com JJROBOTS is a website for robotic projects, online shop, documentation, build instructions, "how it work", forums…

What's in a humanoid hand? | Boston Dynamics
Grippers are one of the most intricate parts of a humanoid robot, packed with actuation and sensing; they need to be durable enough to handle tough jobs, but precise enough to hand…

Air Spot | RL Behavior Research | Boston Dynamics
We take a closer look at what goes into developing new behaviors with Spot using RL research, and why pushing hardware to its limits through athletic feats helps make a better robo…

how to disable a robot dog if it attacks you
Try out the best remote desktop software at hoog.best/anydesk1 PSA. How to protect and survive against a Robot Dog attack. Boston Dynamics, Unitree, Spot.…

How does Atlas learn? | Inside the Lab | Boston Dynamics
Just months after its debut, Atlas is proving why it is the world’s most capable and dynamic humanoid robot, ready for real work. Lifting a mini-fridge is a feat of strength, but t…

Warehouse Robots at Work
IEEE spectrum takes you inside Kiva Systems' robotic warehouse, where orange robots make inventory move instead of workers. Learn more: https://spectrum.ieee.org/three-engineers-hu…

My little piece of privacy
My robotic curtain protects me from nosey looks of pedestrians passing by. More about the project: http://www.niklasroy.com/project/88/my-little-piece-of-privacy Music by @holykonn…

(50X) Autonomously folding a pile of 5 previously-unseen towels
Project was led by UC Berkeley Ph.D. student Jeremy Maitin-Shepard working with Professor Pieter Abbeel. The video is shown at 50X speed. More details can be found in the paper at …

Inside the Robotics Race | Boston Dynamics x Hyundai Motor Group x Bloomberg Media Studios
Why will Boston Dynamics win the humanoid robotics race? We've already commercialized autonomous mobile robots, creating markets with Spot and Stretch. Now we're doing it again wit…

Atlas Getting a Leg up with End-to-end Neural Networks
We are excited to share some of our progress on developing Large Behavior Models (LBMs) for Atlas. This work is part of a collaboration between AI research teams at Toyota Research…

Helix 2.5 30-Home Generalization
Today we’re releasing Helix 2.5 We rented 30 homes in the Bay Area. The robots arrived with no additional training and started doing useful work…
Atlas on a Roll | Classical Motor Controls and Whole-Body RL | Boston Dynamics
Robots in the real world experience challenges and conditions we can’t always anticipate or recreate in the lab, so we have to get creative to push the limits. Adding wheels to Atl…

Figure's First Full HQ Tour: From the Lab to the Factory Floor
For the first time ever, Figure is opening every door. Sourcery gets the first full tour of Figure's robotics campus with Founder & CEO Brett Adcock — and we see everything. Figure…

Playing Catch and Juggling with a Humanoid Robot
Robots in entertainment environments typically do not allow for physical interaction and contact with people. However, catching and throwing back objects is one form of physical en…

Lecture 1 | Introduction to Robotics
Help us caption and translate this video on Amara.org: http://www.amara.org/en/v/mg/ Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Compu…
PaTS-Wheel: A Passively-Transformable Single-Part Wheel for Mobile Robot Navigation
T. Godden*, B. W. Mulvey*, E. Redgrave and T. Nanayakkara, “PaTS-Wheel: A Passively-Transformable Single-Part Wheel for Mobile Robot Navigation on Unstructured Terrain,” IEEE Robot…

Brett Adcock - Shawn Ryan’s First Interview with a Robot | SRS #292
Brett Adcock is a technology entrepreneur focused on building companies in robotics, artificial intelligence, and aerospace. Born and raised on a third-generation farm in central I…

Machine, Assemble, Repair: How We Build Atlas | Boston Dynamics
From custom part to running robot, the Atlas shop floor is built on precision, rapid assembly, and real-time collaboration. By machining parts in-house and streamlining assembly an…

Google DeepMind robotics lab tour with Hannah Fry
In this episode, we open the archives on host Hannah Fry’s visit to our California robotics lab. Filmed earlier this year, Hannah interacts with a new set of robots—those that don'…
Control Bootcamp: Overview
Overview lecture for bootcamp on optimal and modern control. In this lecture, we discuss the various types of control and the benefits of closed-loop feedback control. These lectur…

The Evolution of Stretch | Boston Dynamics
Stretch has moved over a million customer boxes in under a year, improving predictability and preventing injuries. But how did we get there? Discover how we put our expertise in ro…
Marc Raibert: Boston Dynamics and the Future of Robotics | Lex Fridman Podcast #412
Marc Raibert is founder and former long-time CEO of Boston Dynamics, and recently Executive Director of the newly-created Boston Dynamics AI Institute. Please support this podcast …
Programming for Robotics (ROS) Course 1
The slides are available here: https://www.ethz.ch/content/dam/ethz/special-interest/mavt/robotics-n-intelligent-systems/rsl-dam/ROS2017/lecture1.pdf The recording of this course i…

How Boston Dynamics' Spot Robot Learns to Dance!
How does a robot dog learn how to dance? Adam and the Tested team examine and dive into Boston Dynamics' Choreographer software that was behind Spot's recent viral dancing video. W…

Students Create 'JediBot'
Stanford students have created robots that can battle with 'light sabers" against humans as part of a hands-on course in experimental robotics. Related article: http://news.stanfor…

Why Does Atlas Have A Head? #askaroboticist #bostondynamics
Taylor Frey-Baker, a mechanical engineer at Boston Dynamics, answers questions about why the current iteration of Atlas has a head, how the brain of the robot works, and how Atlas …

(Tiny) Reconfigurable Robots at MIT
The device doesn't look like much: a caterpillar-sized assembly of metal rings and strips resembling something you might find buried in a home-workshop drawer. But the technology b…

“AI and Our Economic Future” with Professor Chad Jones
Economic growth is shifting rapidly as new technology emerges. Electricity, semiconductors, and the internet have been transformative, dramatically increasing living standards worl…

Redefining robotics | Carolina Parada
On this episode, Hannah is joined by Carolina Parada, Senior Director and Head of Robotics at Google DeepMind. They explore the recent leap forward in robotic capabilities, highlig…
Evolved Electrophysiological Soft Robots
The research field of evolutionary robotics abstracts some of the major themes in biological evolution (heritable traits, genetic variation, and competition for scarce resources) a…

A-Pod part 2
A-Pod is an ant inspired hexapod robot with a 2 DOF abdomen (tail), a 3 DOF head with large mandibles. 6 legs with 3 DOF each. Total 25 servos. This video demonstrates improved wal…

Robotics' End Game: Nvidia's Jim Fan
Jim Fan, who leads the embodied autonomous research group at Nvidia, returns to AI Ascent to argue that robotics is entering its end game — and that the playbook is already written…

Tearing Down the Unitree Go2: A Robotics Expert's Deep Dive
What if you could own a Boston Dynamics-style robot dog for a fraction of the price? The Unitree Go2 is an advanced, agile, and relatively affordable robotic dog designed for resea…

Stanford's humanoid robot explores an abandoned shipwreck
The robot, called OceanOne, is powered by artificial intelligence and haptic feedback systems, allowing human pilots an unprecedented ability to explore the depths of the oceans in…

The Future of Robotics and Artificial Intelligence (Andrew Ng, Stanford University, STAN 2011)
(May 21, 2011) Andrew Ng (Stanford University) is building robots to improve the lives of millions. From autonomous helicopters to robotic perception, Ng's research in machine lear…

From Prompt to Walking Robot With NVIDIA RTX Spark
AI agents on NVIDIA RTX Spark help developers turn ideas into real-world robots. Astra connects FreeCAD, Blender, and SimReady Foundation to create assets and build training enviro…

Gemini Robotics: Bringing AI to the physical world
Our Gemini Robotics model brings Gemini 2.0 to the physical world. It's our most advanced vision language action model, enabling robots that are interactive, dexterous, and general…

Learning Physical AI: Free Course (reBot Arm + NVIDIA Isaac)
If you want to get started with physical AI and robotics, this is the place to start. In this new series I'm working through "Learning Physical AI: A Sim-to-Real VLA Pipeline with …
Fully autonomous robots are much closer than you think – Sergey Levine
Sergey Levine is one of the world’s top robotics researchers and co-founder of Physical Intelligence. He thinks we’re on the cusp of a “self-improvement flywheel” for general-purpo…

NVIDIA Isaac GR00T N1: An Open Foundation Model for Humanoid Robots
NVIDIA Isaac GR00T N1 is a generalist foundation model for #humanoid #robots, built on the foundations of synthetic data generation and learning in simulation. GR00T N1 features a …


Lecture 2 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Professor Khatib shows a video on Walking Machines then goes …

Giant Robot Project, Part 1
I'm building a giant walking vehicle.... and documenting it.... poorly. Hey, its tough inventing things AND holding a camera!…

The $10 Trillion Bet on Humanoid Robots | Figure Founder Brett Adcock
Brett Adcock is the Founder & CEO of Figure, the $39 billion company tackling one of the most ambitious challenges in technology — building a general-purpose humanoid robot that ca…

Isaac Sim & Isaac Lab: Full Guide to Building & Training Robots
Join NVIDIA GTC and learn more about advanced robotics: https://nvda.ws/3NWQLlS HBADA chair: https://bit.ly/41rti06 — Code for 5% off: NIKODEM HBADA on Amazon : https://amzn.to/45Q…

Scaling Helix - Logistics
Helix can now handle a wider variety of packaging approaching human-level dexterity and speed, bringing us closer to fully autonomous package sorting. This rapid progress underscor…
New NVIDIA Isaac GR00T humanoid AI Robot is mind blowing - World Premiere
Take a look at the all new NVIDIA Isaac GR00T humanoid AI robot. NVIDIA is accelerating the future of humanoid robotics with Isaac GR00T, an advanced artificial intelligence platfo…

The Future of Humanoid Robotics | Jonathan Hurst | TEDxPortland
NOTE FROM TED: TEDx events are independently organized by volunteers. The guidelines we give TEDx organizers are described in more detail here: http://storage.ted.com/tedx/manuals/…

Robotic Deep-Dive: Beating China, the Race Against Tesla, & New Robotics Timeline With Brett Adcock
The Mates sit down with Brett Adcock, founder and CEO of Figure AI, to discuss the global race in humanoid robotics, how Figure AI is competing with China and Tesla, and the latest…

Robotic Distribution
from Kiva Systems and delivered to the online retailer, Zappos.com. For more info, check out Wired Science: http://blog.wired.com/wiredscience/2009/01/retailrobots.html…

Inside the $5.6B Startup Building Robot Brains (Physical Intelligence)
Season 3 Episode 1: Welcome inside the world of Physical Intelligence. Honestly? This was the first time seeing a robot truly impressed us. No staging, no choreography, just real-t…

Why Google Gave Up on Boston Dynamics
Boston Dynamics is one of the most well-known robotics companies out there - but their story isn’t as smooth as it looks. From early DARPA projects to getting bought (and then sold…

Stanford's Robotic Audi to Brave Pikes Peak Without Driver
Stanford engineers have developed a third autonomous vehicle. The car, named Shelley, is scheduled to race up Pikes Peak without a driver at the end of the summer. Stanford Univers…

Snail-inspired robotic swarms
Authors: Da Zhao, Haobo Luo, Yuxiao Tu, Chongxi Meng, Tin Lun Lam Corresponding author: Tin Lun Lam (Email: tllam@cuhk.edu.cn; Website: https://sites.google.com/site/lamtinlun ) P…
Gemini Robotics 1.5: Enabling robots to plan, think and use tools to solve complex tasks
We’re powering an era of physical agents with Gemini Robotics 1.5 — enabling robots to perceive, plan, think, use tools and act to better solve complex, multi-step tasks. 🤖 Gemini …

Modern Robotics, Chapter 2.2: Degrees of Freedom of a Robot
This is a video supplement to the book "Modern Robotics: Mechanics, Planning, and Control," by Kevin Lynch and Frank Park, Cambridge University Press 2017. See http://modernrobotic…

Controllability [Control Bootcamp]
This lecture explores when a linear system is controllable. We begin with the simple test in terms of the rank of the controllability matrix on a few intuitive examples. Chapters a…

Modern Robotics, Chapter 8.1: Lagrangian Formulation of Dynamics (Part 1 of 2)
This is a video supplement to the book "Modern Robotics: Mechanics, Planning, and Control," by Kevin Lynch and Frank Park, Cambridge University Press 2017. See http://modernrobotic…
Lecture 1 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 1: Introduction Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://ocw.mit.ed…

Design and Control of a Bipedal Robotic Character
Legged robots have achieved impressive feats in dynamic locomotion in challenging unstructured terrain. However, in entertainment applications, the design and control of these robo…

Dyson 360 Eye™ A robot vacuum that sees all around the room at once
Discover how the Dyson 360 Eye™ uses vision technology to map the whole room and clean efficiently. Without vision, many robots rely on blindly feeling out their environment and en…

Boston Dynamics New Atlas Upgrade Just Breaks the Limits of Movement
Boston Dynamics just transformed Atlas with a radical new way to move, letting it drift, slide, and land a 360-degree spin jump on its first real-world try. The upgrade takes only …

The artificial muscles that will power robots of the future | Christoph Keplinger
Robot brains are getting smarter and smarter, but their bodies are often still clunky and unwieldy. Mechanical engineer Christoph Keplinger is designing a new generation of soft, a…

Google DeepMind Demos AI Training Robots to Play Soccer / Football
DeepMind, the AI startup acquired by Google, demos how AI and sports is used to train robots to play soccer (football) for wider potential use cases. Featured on 60 Minutes on Sund…

Why This Is My Favorite Robot Build Yet
Engineered to inspire my son's curiosity 👉 Build your own: https://microbots.io/ProtoBot Huge thanks to PCBWay for manufacturing the Flex PCB prototypes: https://www.pcbway.com 🧠 P…

This robot can beat you at table tennis
For the first time, an AI-powered machine has bested elite-level athletes at a physical sport. 'Ace' is a table tennis-playing robot. It can calculate the position of a ball in spa…

The Humanoid Mission in Manufacturing | Boston Dynamics Tech Talk
In this conversation, Zack Jackowski, General Manager and Vice President, Atlas and Alberto Rodriguez, Director of Robot Behavior sit down to discuss the path to generalist humanoi…

Stanford's 'Stickybot,' a Gecko-like robot, climbs vertical services
Mechanical Engineering PhD Student Salomon Trujillo watches 'Stickybot" go through its paces.…

Tour the state-of-the-art Stanford Robotics Center
The Stanford Robotics Center brings together cross-disciplinary world-class researchers with a shared vision of robotics’ future. Stanford’s robotics researchers, once dispersed in…

Surprisingly STEM: Soft Robotics Engineers
‘Doing the robot’ on the dancefloor would look more like ‘doing the worm’ if the dance move was inspired by soft robots! Soft robotics is an exciting sub-category of robotics that …

Lecture 3 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Professor Khatib shows a short video on Flexible Microactuato…

6-Axis FANUC Industrial Robot PROGRAMMING| FREE CLASS FOR INDUSTRIAL ROBOTICS | RVM CAD
This video will explain how an industrial robot works. RVM CAD is the only training center in India which has a 6-Axis FANUC industrial robot at its training lab. Book Free Career …

What is ROS in less than 150 seconds! #robot #ros #robotics
🤖 What is ROS? In under 150 seconds, learn what Robot Operating System (ROS) is and why it’s a game-changer in modern robotics! From controlling robots to managing sensors and data…

Narrowing the Sim2Real Gap with NVIDIA Isaac Sim
Training and developing intelligent robots in simulation to be successfully deployed in the real world is challenging. The robot’s interactions and senses in the virtual world shou…

Hod Lipson: Robots that are "self-aware"
http://www.ted.com Hod Lipson demonstrates a few of his cool little robots, which have the ability to learn, understand themselves and even self-replicate. TEDTalks is a daily vide…

How Robots Learn to Be Robots: Training, Simulation, and Real World Deployment
Everything that moves will be autonomous and #physicalAI will embody robots of every kind. Explore the continuous loop of #robot AI simulation, training, testing, and real-world ex…

Lecture 4 | Introduction to Robotics
Help us caption and translate this video on Amara.org: http://www.amara.org/en/v/8lM/ Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Comp…

Stanford exoskeleton walks out into the real world
For years, the Stanford Biomechatronics Laboratory has captured imaginations with their exoskeleton emulators – lab-based robotic devices that help wearers walk and run faster, wit…

Modern Robotics, Chapter 3.3.1: Homogeneous Transformation Matrices
This is a video supplement to the book "Modern Robotics: Mechanics, Planning, and Control," by Kevin Lynch and Frank Park, Cambridge University Press 2017. See http://modernrobotic…

One Brain, Any Body: Google DeepMind's Keerthana on Gemini Robotics 2, Cross-Embodiment & Humanoids
Keerthana Gopalakrishnan, Research Lead for Gemini Robotics at Google DeepMind, returns to discuss the release of Gemini Robotics 2, whole-body intelligence, and the pursuit of gen…

Intelligent whole-body control with Gemini Robotics 2
The world is built for human movements; it requires us to reach, bend, and balance in tight, cluttered spaces. While our previous models controlled the humanoid’s upper-body to ach…

Chelsea Finn: This is the State of the Art in Robotics
Robots can already fold laundry, make espresso, clean kitchens, and assemble things. The harder problem is getting them to do those tasks reliably, for long periods of time, withou…

Jared Friedman - Advice for Hard-tech and Biotech Founders
YC Partner Jared Friedman covers hard-tech companies and why founders should consider starting one. He also covers a couple of the most common problems hard-tech companies face and…

Amazon Robotics Deploys First Fully Autonomous Robot With NVIDIA Isaac Sim
Amazon Robotics has manufactured and deployed the world's largest fleet of mobile industrial robots. The newest member of this robotic fleet is Proteus—Amazon's first fully autonom…

Stanford Students' Dueling Robots
Best finals project ever? Stanford students in the 'Introduction to Mechatronics' course build robots to do battle, sumo wrestler-style, to display their mastery of combining mecha…
Lecture 5 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Professor Khatib shows a short video on the Brachiation Robot…
Introduction to Robotics at MIT
In this year’s Class 2.12: Introduction to Robotics, taught by Professor Harry Asada and Professor Kamal Youcef-Toumi, undergraduate students joined forces to build a robot that co…

Google I/O 2011: Cloud Robotics
Ryan Hickman, Damon Kohler, Ken Conley, Brian Gerkey Learn how developers can accelerate the pace of robotics research and development and make high functioning robots affordable a…

Next Gen Atlas AI Robot (by Boston Dynamics) can do what humans do - World Premiere
Discover the all new Boston Dynamics Atlas robot, featuring advanced AI, electric mobility, powerful robotic hands and industrial automation. Boston Dynamics has unveiled a new gen…

Daniel Suarez: The kill decision shouldn't belong to a robot
As a novelist, Daniel Suarez spins dystopian tales of the future. But on the TEDGlobal stage, he talks us through a real-life scenario we all need to know more about: the rise of a…

Amazon Robotics Builds Digital Twins of Warehouses with NVIDIA Omniverse and Isaac Sim
Amazon’s over 200 fulfillment centers handle tens of millions of packages per day, a complex operation requiring over half a million mobile drive robots to support warehouse logist…
30 Home Generalization
Yesterday we announced Helix 2.5 We rented 30 homes in the Bay Area. The robots arrived with no additional training and started doing useful work Here's 4 hours of continuous work …

Rolling in the Deep – Hybrid Locomotion for Wheeled-Legged Robots
Our quadrupedal robot ANYmal equipped with actuated wheels performs dynamic hybrid walking-driving motions. Journal article accepted to IEEE Robotics and Automation Letters (RA-L) …

Your First Personal Robot
Order now: https://www.kscale.dev/ We believe robots should serve people and empower anyone to build the future. That’s why we created K-Bot: the first full-size humanoid robot you…
Lecture 8 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Professor Khatib shows a short video on Mobile Robots: Automa…

Zipline's $21.5B Bet on Teleportation
It was illegal to fly autonomously in US airspace when Keller Cliffton started Zipline, and most investors "weren't willing to invest in illegal things." Zipline launched in Rwanda…

This Humanoid Robot Just Got Human-Level Hands. Here's the Man Behind It | 1X, Bernt Børnich
*This interview was filmed in May 2025. 1X Founder & CEO Bernt Børnich has spent the past 10 years chasing one mission — building robots that move, learn, and live among people. Fr…
Lecture 11 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Professor Khatib shows a short video on The Robotic Reconnais…
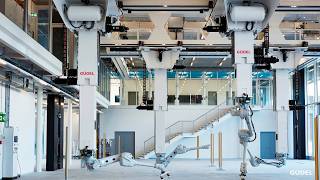
Multi-Robot Gantry System at ETH Zurich, Robotic Fabrication Lab
Discover how Güdel's customized Multi-Robot Gantry System enables advanced robotic fabrication and opens up new possibilities in digital construction and architecture. Installed at…

Boston Dynamics Goes Full AI With New Atlas Robot
Boston Dynamics is turning Atlas into a real AI factory worker inside Hyundai’s plants, while Spot gets AI agents and Google Gemini. Meanwhile Hyundai prepares to scale robotics to…

Training a Robot from Scratch in Simulation, from URDF to OpenUSD
Learn how to train robots from scratch using simulation. In this session, Muammer Bay from LycheeAI walks through each step for training the SO-100 arm — starting from a basic URDF…

Lecture 1 | MIT 6.832 (Underactuated Robotics), Spring 2020 | Why study dynamics?
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2020/…

NVIDIA Isaac GR00T N1 Robot REVEAL
NVIDIA today announced a portfolio of technologies to supercharge humanoid robot development, including NVIDIA Isaac GR00T N1, the world’s first open, fully customizable foundation…

Advanced dexterity with Gemini Robotics 2
To be genuinely useful in our homes and workplaces, robots need finesse. Gemini Robotics 2 unlocks a new level of physical dexterity across different end effectors, whether a robot…

Accelerating Robot Development With AI Agents and NVIDIA Isaac
From prompts and data to real-world robot skills, frontier AI agents build training worlds, replay real-world motion, and tune physics using NVIDIA open libraries and models. Skill…

Accelerating Humanoid Robot Development With NVIDIA Isaac GR00T
General-purpose humanoid robots represent the next leap in AI, but development remains fragmented. Developers spend significant time setting up robotics infrastructure before they …

High Speed Whole Body Dynamic Motion Experiment with Real Time Master-Slave Humanoid Robot System
ICRA 2018 Spotlight Video Interactive Session Thu AM Pod I.7 Authors: Ishiguro, Yasuhiro; Kojima, Kunio; Sugai, Fumihito; Nozawa, Shunichi; Kakiuchi, Yohei; Okada, Kei; Inaba, Masa…
Lecture 10 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Guest lecturer Krasimir Kolarov (co-writer of the lecture not…
Lecture 16 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. For the last meeting of the quarter, Professor Khatib shows a…
Lecture 9 | Introduction to Robotics
Lecture by Professor Oussama Khatib for Introduction to Robotics (CS223A) in the Stanford Computer Science Department. Guest lecturer Gregory Hager covers Perception and Sensing in…

RI Seminar: Yuke Zhu : Toward Generalist Humanoid Robots
https://www.ri.cmu.edu/event/toward-generalist-humanoid-robots-recent-advances-opportunities-and-challenges/ Yuke Zhu Associate Professor Department of Computer Science, University…

Intro to Continuum Mechanics Lecture 1 | Mathematical Preliminaries
Intro to Continuum Mechanics Lecture 1 | Mathematical Preliminaries Contents: Introduction: (0:00) Course Outline: (5:36) eClass Setup: (13:29) Lecture: (33:03)…

How does Atlas learn? | Inside the Lab | Boston Dynamics
Just months after its debut, @BostonDynamics' Atlas is proving why it is the world’s most capable and dynamic humanoid robot, ready for real work. Lifting a mini-fridge is a feat o…

My journey at ETH Zurich as a Masters student
This video portrays the main aspects of my life as a Masters student at ETH Zurich, my struggles, mindset and any advice to prospective students. It was made in collaboration with …

State-of-the-art Legged Robots at the 4th ICRA 2020 Workshop in Paris (Teaser)
State-of-the-art legged robots are showcased during the 4th full-day workshop "Towards Real-World Deployment of Legged Robots" at ICRA 2020 (31 May to 4 June 2020) in Paris, France…

Gemini Robotics 1.5: Learning across embodiments
Robots come in all shapes and sizes, and have different sensing capabilities and different degrees of freedom, making it difficult to transfer motions learned from one robot to ano…

Stanford Robotics Seminar ENGR319 | Winter 2025 | Embodied Intelligence
For more information about Stanford’s graduate programs, visit: https://online.stanford.edu/graduate-education March 7, 2025 This seminar covers: • Embodied intelligence with morph…

Modern Robotics, Chapter 6: Inverse Kinematics of Open Chains
This is a video supplement to the book "Modern Robotics: Mechanics, Planning, and Control," by Kevin Lynch and Frank Park, Cambridge University Press 2017. See http://modernrobotic…

RI Seminar: Max Simchowitz: Generative Control, Action Chunking, and Moravec’s Paradox
https://www.ri.cmu.edu/event/generative-control-action-chunking-and-moravecs-paradox/ Max Simchowitz Machine Learning Department, Robotics Institute Carnegie Mellon University Marc…

Multi-robot collaboration with Gemini Robotics 2
Multi-robot collaboration enables different types of robots to communicate and work together to solve complex problems. Learn more about Gemini for Robotics 2: https://deepmind.goo…

OpenAI Robotics Symposium 2019
9:15 AM (0:46:41) Opening (Matthias Plappert, OpenAI) 9:30 AM (0:57:22) Learning Dexterity (Wojciech Zaremba, OpenAI) 10:15 AM Coffee Break & Demo 10:45 AM (2:12:28) Learning from …

A Day in the Life of a Robotics PhD Student at Carnegie Mellon University | Yorai Shaoul
Come along for the (autonomous) ride with Yorai Shaoul, and see what a day is like for a Ph.D. student at Carnegie Mellon University Robotics Institute. Music: Dubstep, Moose, Funk…

π0.5: a VLA with Open-World Generalization
Robots have made impressive strides—from acrobatic feats and dance performances to practical tasks like folding laundry and clearing tables. Yet, one challenge remains paramount: g…

Lecture 1 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

MIT robot falling out of the car | Russ Tedrake and Lex Fridman
Full episode with Russ Tedrake (Aug 2020): https://www.youtube.com/watch?v=A22Ej6kb2wo Clips channel (Lex Clips): https://www.youtube.com/lexclips Main channel (Lex Fridman): https…

Streamline Data Collection With NVIDIA Isaac GR00T
Developing general-purpose robot models requires massive amounts of real-world data, which is costly to capture and curate. NVIDIA Isaac™ GR00T helps tackle these challenges, provi…

Figure AI’s Humanoid Robots F.03 Are Sorting Packages 24/7 — Fully Autonomous?
Figure AI just livestreamed its F.03 humanoid robots working nonstop inside a real warehouse for over 7 days. The robots autonomously identified, scanned, and sorted nearly 200,000…

Stanford students build autonomous robots for 'Botcoin Bonanza'
After weeks of lectures, students in ME 210: Introduction to Mechatronics face a final project like none other: Build a robot from scratch and put it to battle. This year's challen…

Behind the scenes with Genie 4
Go behind the scenes of our recent Genie 4 film as we explore our most realistic and interactive world model yet. Instead of generating static video, Genie 4 simulates dynamic worl…

Stanford Homecoming: Allison Okamura and Debbie Senesky
Two Stanford Engineering professors discuss their research during the 2017 Stanford Reunion/Homecoming event. First up is professor of mechanical engineering Allison Okamura, who g…
RI Seminar: Russ Tedrake: Robust motion planning for walking robots and robotic birds
Robust motion planning for walking robots and robotic birds Russ Tedrake Associate Professor, MIT October 28, 2011 Abstract Building robots that can walk or fly with the dexterity …

Student Robots Clash in Class Finale
Class finals aren't usually witnessed by hundreds of cheering spectators. But that's what happened when Introduction to Mechatronics drew to a close with a showdown among student-b…

Robo-show-and-tell: Stanford Students present autonomous robots
Experimental Robotics students put their programming chops to work by teaching robots to play golf, stack dominoes and swat balloons.…

Lecture 3 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 3: Optimal control of the double integrator Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More info…

Introducing Gemini Robotics 2
Carolina Parada, Stuart Bowers, Kanishka Rao, and Jie Tan from Google DeepMind join host Logan Kilpatrick inside the Gemini Robotics Lab to introduce Gemini Robotics 2, Google Deep…
Lecture 1 for MIT 6.832 (Underactuated Robotics) 2015
6.832 Lecture 1…

Robots working together with Gemini Robotics 2
Introducing multi-robot collaboration. This enables different types of robots to communicate and work together to solve complex workflows a single robot could not do alone. Learn m…

Learning by Watching Human Videos
Humans learn by watching. Why can’t robots do the same? Our model learns new skills by watching human videos. See our robot open doors, water plants, assemble a box, and more by wa…

Tough dexterity tasks with Gemini Robotics 2
To be genuinely useful in our homes and workplaces, robots need finesse. Gemini Robotics 2 unlocks a new level of physical dexterity across different end effectors, whether a robot…
RI Seminar: Michael Kaess : Robust and Efficient Real-time Mapping for Autonomous Robots
Michael Kaess Assistant Research Professor, Carnegie Mellon University, Robotics Institute Robust and Efficient Real-time Mapping for Autonomous Robots Abstract We are starting to …

RI Seminar: Jeff Schneider : Self Driving Cars and AI
Jeff Schneider Research Professor Robotics Institute, Carnegie Mellon University February 15, 2019 Self Driving Cars and AI: Transforming our cities and our lives Abstract: Artific…

RI Seminar: Yong-Lae Park : Bio-Inspired Soft Robotics: New Ways of Sensing and Actuation
Bio-Inspired Soft Robotics: New Ways of Sensing and Actuation Yong-Lae Park Assistant Professor, Carnegie Mellon, Robotics Institute September 19, 2014 Abstract Innovation in sensi…

Figure AI Reveals New 04 Humanoid Robot Hardware Upgrades (GENIE 4)
Can an AI humanizer pass Pangram without wrecking your writing? I tested StealthGPT Super on an AI-generated newsletter draft, ran it through Pangram and a second AI detector befor…

Figure 03 AI Robot Reveals Its UNFAIR Advantage… Humans Can’t Match It
🚨 A 22-year-old intern just beat a humanoid robot… but this might be the LAST time a human wins like this. In Figure AI's wild Man vs Machine livestream, intern Aimé Gérard went he…
Lecture 1: MIT 6.832 Underactuated Robotics (Spring 2022) | "Robot dynamics and model-based control"
Slides: https://slides.com/russtedrake/spring22-lec01 Due to technical difficulties with the projector, this lecture is slightly out of sync with the posted slides. For a lecture b…

Laser Coating Removal for Aircraft
http://www.rec.ri.cmu.edu/projects/ctc/…


Lecture 4 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 4: Optimal control of the double integrator (continued) Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-…

MIT CSAIL Office Hours: Robotics | Episode 1
3 labs. Different robotic solutions of the future. Videographer: Mike Grimmett Director: Rachel Gordon PA: Alex Shipps…

Stanford students design autonomous robots that mimic self-driving cars
Students programmed robots to autonomously navigate an unknown city-scape and aid in a simulated rescue of animals in peril in a class that mimics the programming needed for autono…

We took our Robot Hiking in the Alps
A behind-the-scenes day with ANYmal on a 2.4 km hike around Seealpsee in the Swiss Alps. Gravel paths, grass, the lake edge and cows on the trail. On 25 June 2024 the team drove AN…
Lecture 5 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 5: Numerical optimal control (dynamic programming) Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA Mo…

Train Robots With 40 Demos Instead of 1000s: Complete GR00T Developer Tutorial
Learn to train robots with NVIDIA Isaac GR00T and robot learning. In this video, you’ll learn how to post-train the Isaac GR00T N1.5 foundation model, enabling robot training with …
Stanford Seminar - Robot Learning in the Era of Large Pretrained Models
February 23, 2024 Dorsa Sadigh, Stanford University In this talk, I will discuss how interactive robot learning can benefit from the rise of large pretrained models such as foundat…

ETH Zurich @ ERL Emergency Robotics 2017
The Robotic Systems Lab and the Autonomous Systems Lab are competing as a team at the ERL Emergency Robotics 2017 in Piombino, Italy.…

Watch Your Step: Anticipated Perception for Humanoid Locomotion
Where should a humanoid look while it walks? Where its feet are about to land. Watch Your Step trains a lightweight foothold prediction model (FPM) alongside a locomotion policy. T…
RI Seminar: Jitendra Malik : Robot Learning, With Inspiration From Child Development
Jitendra Malik Arthur J. Chick Professor of EECS / VP and Distinguished Scientist University of California at Berkeley / Amazon February 13, 2026 https://www.ri.cmu.edu/event/robot…
Scientific Exploration of Challenging Planetary Analog Environments with a Team of Legged Robots
We present a team of legged robots for scientific exploration missions in challenging planetary analog environments. The paper was published in Science Robotics and we deployed thi…

Building the general-purpose robotic brain
Modern AI is confined to the digital world. At Skild AI, we are building towards AGI for the real world, unconstrained by robot type or task — a single, omni-bodied brain. Today, w…

Cloud Robotics Intro | Ken Goldberg | Talks at Google
Ken Goldberg, UC Berkeley and Matei Ciocarlie, Google Ken Goldberg is the craigslist Distinguished Professor of New Media and Professor of Industrial Engineering and Operations Res…

RI Seminar: Sidd Srinivasa: Robotic Manipulation...
Robotic Manipulation under clutter and uncertainty with and around people Sidd Srinivasa Associate Professor, RI, Carnegie Mellon Abstract Robots manipulate with super-human speed …
Martial Hebert : Director of the Robotics Institute at CMU SCS
Martial explains why Carnegie Mellon University is a beautiful place to do robotics research and talks about many of the exciting things going on here at the Robotics Institute Apr…

Stanford AA274A Principles of Robotic Autonomy | Autumn 2019 | Stereo Vision
For more information about Stanford’s graduate programs, visit: https://online.stanford.edu/graduate-education Lecture 10 — Stereo Vision Note: This lecture was recorded as part of…

π0: Our First Generalist Robotic Policy
Over the past eight months we’ve developed a general-purpose robotic foundation model, which we call π0. We hope this will be a first step toward our long-term goal of developing a…

Physical AI: the new era of robotics
Join scientific leaders from Google DeepMind and Boston Dynamics as they unpack the seismic leap in embodied AI. This session will examine how machines are moving beyond scripted a…

Robot Programming With NOVA & NVIDIA Isaac Sim
Join us for an exclusive livestream as we explore how Wandelbots' NOVA integration with NVIDIA's Isaac Sim advanced simulation capability is reshaping robot motion planning and exe…

RI Seminar : Pieter Abbeel : Deep Learning for Robotics
Pieter Abbeel Professor Director, Berkeley Robot Learning Lab & Co-Director, Berkeley Artificial Intelligence (BAIR) Lab, UC Berkeley https://www.ri.cmu.edu/event/ri-seminar-pieter…
Lecture 10 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 10: Trajectory stabilization and iterative linear quadratic regulator (iLQR) Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Cr…

RI Seminar: Sangbae Kim : Physical Intelligence and Cognitive Biases Toward AI
https://www.ri.cmu.edu/event/physical-intelligence-and-cognitive-biases-toward-ai/ Sangbae Kim Professor Mechanical Engineering, Massachusetts Institute of Technology April 11, 202…

Every Confusing Thing About Robotics Explained Slowly (For Sleep)
Now streaming on Spotify https://open.spotify.com/show/033FVSzn7RbNG80loJjcRf How did robots evolve from simple mechanical automata into machines that can walk, learn, see, grasp o…

Building and Testing Autonomous Delivery Robots in NVIDIA Isaac Sim
Autonomous sidewalk delivery is one of the most complex and exciting challenges in robotics. Serve Robotics is building fleets of robots designed to safely navigate city streets, d…

Planetary Robotics at Carnegie Mellon University | Empowering Innovation Together with Grant Imahara
Planetary robotics and the creation of Terregator for the Urban Challenge, Dr. Martial Hebert of Carnegie Mellon University. Alongside Grant Imahara, they look at Terregator, desig…

Getting Started with NVIDIA Isaac Sim & Isaac Lab on Brev | Robotics Office Hours
Join us for our next Robotics Office Hours to see how Brev makes it easy to run Isaac Sim and Isaac Lab, powerful frameworks for robotics simulation, training, and learning on NVID…
Lecture 6 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 6: Acrobot and cart-pole Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://o…

RI Seminar: Abhishek Gupta : Simulation-Driven Robot Learning for the Lazy Researcher
Abhishek Gupta Assistant Professor Computer Science and Engineering, University of Washington October 23, 2026 https://www.ri.cmu.edu/event/simulation-driven-robot-learning-for-the…

Smart SPHERES: Free-Flying Space Robots | Mark Micire | Talks at Google
"NASA is using Nexus S phones on the International Space Station as an upgrade for a trio of volleyball-sized SPHERES (Synchronized Position Hold, Engage, Reorient, Experimental Sa…
Lecture 7 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 7: Swing-up control of acrobot and cart-pole systems Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA …

One Brain, Any Robot: Skild AI's Skild Brain Explained | NVIDIA AI Podcast Ep. 295
What if one AI brain could run every robot on the planet—a humanoid, a warehouse arm, and a dog-like inspection bot—all at once? That's not a thought experiment. That's what Skild …
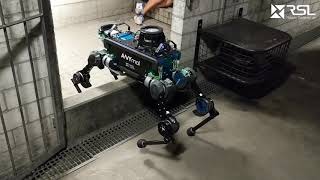
ANYmal for Search and Rescue Missions
ANYmal, a quadrupedal robot developed by RSL (ETH Zurich) and ANYbotics, is deployed in real-world environments for search and rescue missions. Credits: Marco Tranzatto, Marko Bjel…

Robots, Inventors Take Center Stage at Stanford Event
Academics, commercial robot manufacturers and hobbyists showed off their skills and creations at Stanford's second-annual Robot Block Party. Related article: http://news.stanford.e…

Lecture 9 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 9: Trajectory optimization Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http:/…

Our Robots, Ourselves | David Mindell | Talks at Google
David Mindell visited Google's office in Los Angeles, CA to discuss his book "Our Robots, Ourselves: Robotics and the Myths of Autonomy". This talk was on October 22, 2015.…
Lecture 8 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 8: Dynamic programming (DP) and policy search Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More in…

MIT entry to DARPA Robotics Challenge | Russ Tedrake and Lex Fridman
Full episode with Russ Tedrake (Aug 2020): https://www.youtube.com/watch?v=A22Ej6kb2wo Clips channel (Lex Clips): https://www.youtube.com/lexclips Main channel (Lex Fridman): https…

Heaphy - Cloud Robotics
Humanoid robot control via crowdsourcing. See: https://spectrum.ieee.org/automaton/robotics/robotics-software/the-heaphy-project…

CMU Robotics Institute - A PHD Tales from the Road
**ORDER our new book: http://WeHaveNoIdea.com In this archival footage, Jorge visits the Carnegie Mellon University Robotics Institute. Visit our website: http://phdcomics.com/tv S…

Lecture 2 for MIT 6.832 (Underactuated Robotics) 2015
6.832 Lecture 2…

Robot Cooking Eggs -- Live Demo
Skild AI CEO Deepak Pathak (@pathak2206) gives a live tour of Skild AI's robots to Prof. Alexei A. Efros from UC Berkeley. The same base model, Skild Brain, adapts from cooking egg…

Learning in Humans and Robots
(April 1, 2009) Trevor Blackwell…

FANUC CNC Simulation training
Kentucky Manufacturer STOBER Drives Upskills its Workforce with FANUC CNC Training Tools STOBER Drives USA’s apprenticeship program trains new hires as well as high school recruits…

Stanford Seminar - Deploying Autonomous Service Mobile Robots, And Keeping Them Autonomous
Joydeep Biswas - https://www.joydeepb.com/ UT Austin April 15, 2022 Why is it so hard to deploy autonomous service mobile robots in unstructured human environments, and to keep the…

RI Seminar: William (Red) Whittaker : 30 Years of the CMU Field Robotics Center
William (Red) Whittaker Head of the Field Robotics Center, Carnegie Mellon University October 11, 2013 Abstract Field Robotics is automation's breakaway success story. The technolo…
Lecture 11 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 11: Walking Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://ocw.mit.edu/te…

A closer look: Stanford Robotics Center tour
We got a glimpse of the future on Friday courtesy of robotics, artificial intelligence, and some of the smartest young people in the Bay Area. Scott Budman has the details. Stay co…

RI Seminar: Matthew T. Mason : Robotics and Warehouse Automation at Berkshire Grey
https://www.ri.cmu.edu/event/ri-seminar-matthew-t-mason-cmu-2021-11-19/ Matthew T. Mason Professor Emeritus Robotics Institute, Carnegie Mellon University Friday, November 12, 2021…

Neural Network Basics for Image Interpretation by C. Stachniss (PILS Lecture)
Neural Network Basics for Image Interpretation by Cyrill Stachniss. The PhenoRob Interdisciplinary Lecture Series called PILS is a series of lectures of up to 30 min explaining key…

RI Seminar: Ben Burchfiel : Learning in Production: Building Physical AI at Walden Robotics
Ben Burchfiel Co-Founder & CTO Walden Robotics November 6, 2026 https://www.ri.cmu.edu/event/learning-in-production-building-physical-ai-at-walden-robotics/ Learning in Production:…

Lecture 16 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 16: Introducing stochastic optimal control Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More infor…
Lecture 23 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 23: Case studies in computational underactuated control Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-…

RI Seminar: Andrea Bajcsy : Towards Open World Robot Safety
Andrea Bajcsy Assistant Professor Robotics Institute, Carnegie Mellon University February 14, 2024 Towards Open World Robot Safety Abstract: Robot safety is a nuanced concept. We c…

RI Seminar: Stelian Coros : Personalized Robotic Devices
Computational Design, Fabrication and Control for Personalized Robotic Devices Stelian Coros Assistant Professor, RI, Carnegie Mellon December 04, 2015 Abstract Robots have fundame…

RI Seminar: Negar Mehr : How Can Robots Learn to Interact and Coordinate with Others?
Negar Mehr Assistant Professor Mechanical Engineering Department, University of California at Berkeley October 9, 2026 How Can Robots Learn to Interact and Coordinate with Others? …

Lecture 22 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 22: Actor-Critic methods Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://o…

Figure AI Humanoid Robots Worked 17 HOURS and Sorted 22,000 Packages!
Figure AI just showed its Helix 02 humanoid robots working a massive autonomous warehouse-style shift — sorting more than 22,000 packages over 17+ hours. https://www.figure.ai/ Thi…

Build a Household Robot Workflow With NVIDIA Isaac and Cosmos
Join NVIDIA Omniverse Ambassador Kimate Richards, Founder of 10Things, and Oliver Choy, COO of 10Things, for a practical look at how one real robot uses the NVIDIA robotics stack. …

Lecture 12 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 12: Walking (continued) Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://oc…

Stanford Engineering's Allison Okamura describes how haptics brings human touch to life
http://stanford.io/1pkv9wv: Stanford University School of Engineering's Allison Okamura, an associate professor of mechanical engineering, describes how haptic technology works and…

Get it Done with Liquid Bag Palletizing by Simplimatic
Simplimatic, a FANUC Authorized System Integrator specializes in the design and integration of robotic systems that help their customers solve a wide range of production challenges…
Lecture 14 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 14: Feasible motion planning Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http…

Lecture 10 | MIT 6.832 (Underactuated Robotics), Spring 2019
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2019…

Lights-Out 3D Printing
Achieve Lights-Out Production with Athena 3D’s Automated Additive Manufacturing Solution Athena 3D, a leading additive manufacturing service bureau in Tempe, AZ, has revolutionized…

FANUC MT-LINKi: Real-Time Shop Floor Data
The Kentucky manufacturer of drive solutions standardized its CNC machines on the FANUC platform for easier operations. When the company began searching for IIOT software to provid…

Lecture 17 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 17: Stochastic Gradient Descent Instructor: John W. Roberts See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at h…
RI Seminar: Thomas Howard : Learning Models for Robot Decision Making
Thomas Howard Assistant Professor, University of Rochester February 26, 2016 Abstract The efficiency and optimality of robot decision making is often dictated by the fidelity and c…

Lecture 4: MIT 6.832 Underactuated Robotics (Spring 2022) | "Dynamic Programming II"
Slides available at: https://slides.com/russtedrake/spring22-lec04…

Lecture 19 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 19: Temporal difference learning Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at …

WayTrace: A Map-to-Language-to-Trace Hierarchy for Embodied Urban Navigation
WayTrace connects web-map directions to robot motion through language. An off-the-shelf vision-language model reads the turn-by-turn directions, a satellite map and recent camera i…

Lecture 15 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 15: Global policies from local policies Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More informat…


Lecture 8.1: Russ Tedrake - MIT's Entry in the DARPA Robotics Challenge
MIT RES.9-003 Brains, Minds and Machines Summer Course, Summer 2015 View the complete course: https://ocw.mit.edu/RES-9-003SU15 Instructor: Russ Tedrake MIT's DARPA Robotics Challe…

Google Gemini Robotics | Google Deepmind AI Model for Robots - Demo and Explained
Google’s Gemini Robotics is here! This week, Google DeepMind unveiled a groundbreaking AI model designed to bring robots closer to human-like intelligence. These advanced robots ca…

Lecture 20 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 20: Temporal difference learning with function approximation Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons B…

RI Seminar: Deepak Pathak : Learning to Generalize beyond Training
https://www.ri.cmu.edu/event/ri-seminar-deepak-pathak-cmu-2020-11-20/ Deepak Pathak Assistant Professor Robotics Institute, Carnegie Mellon University Abstract: Generalization, i.e…

Lecture 9 | MIT 6.832 (Underactuated Robotics), Spring 2020 | Computing Lyapunov II
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2020/…
Stanford Seminar - Robots in Dynamic Tasks: Learning, Risk, and Safety
March 10, 2023 Joel Burdick of Caltech Autonomous robots are increasing applied to tasks that involve complex maneuvers and dynamic environments that are difficult to model a prior…
Lecture 21 | MIT 6.832 Underactuated Robotics, Spring 2009
Lecture 21: Policy improvement Instructor: Russell Tedrake See the complete course at: http://ocw.mit.edu/6-832s09 License: Creative Commons BY-NC-SA More information at http://ocw…
Carolina Parada on Gemini Robotics and Google DeepMind’s Physical AI Strategy
Ten years ago, Google DeepMind’s robotics team believed a single model could learn to go from pixels to motor control. People thought the idea was crazy. Now, many of the same idea…

Stanford Seminar - Modeling and interacting with other agents, Claire Tomlin
Claire Tomlin, UC Berkeley May 27, 2022 One of the biggest challenges in the design of autonomous systems is to effectively predict what other agents will do. Reachable sets comput…


In the Spotlight: Sidd Srinivasa, associate professor, CMU Robotics Institute
Sidd Srinivasa's goal is to enable robots to robustly and gracefully interact with the world to perform complex manipulation tasks in uncertain, unstructured, and cluttered environ…

From Human Demonstrations to Robot Training Data With RLWRLD and Reactor | Cosmos Labs
How do you turn a video of someone working into training data a robot can learn from? Join NVIDIA, RLWRLD, and Reactor to explore a pipeline that connects human demonstrations to r…

Stanford Robotics Seminar ENGR319 | Autumn 2026 | Bridging Rigorous Methods with Machine Learning
For more information about Stanford’s graduate programs, visit: https://stanford.io/grad-ed-engr319-1002 October 2, 2026 This seminar covers: • Why learning-based controllers strug…

How does Atlas learn? | Inside the Lab | Boston Dynamics
Just months after its debut, Atlas is proving why it is the world’s most capable and dynamic humanoid robot, ready for real work. Lifting a mini-fridge is a feat of strength, but t…
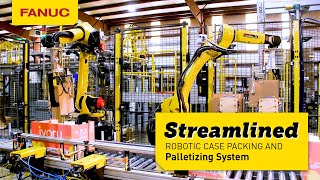
Streamlined Robotic Case Packing and Palletizing System
Kaufman Engineering, an authorized FANUC System Integrator, developed a robotic case packing and palletizing system for manufacturing and distribution. Here’s how it works: 1. Bott…

RI Seminar: Henny Admoni : Understanding Human Behavior for Robotic Assistance and Collaboration
Henny Admoni Assistant Professor Robotics Institute, Carnegie Mellon University April 11, 2019 Human-robot collaboration has the potential to transform the way people work and live…

Automated Tire Strapping Line Improves Efficiency and Safety
Integrated Industrial Technologies, Inc. (I2T) partnered with Greenbridge to deliver a fully automated tire strapping solution using a high-speed FANUC M-410iC/185 palletizing robo…

Faculty Spotlight: Howie Choset, Robotics Institute, CMU School of Computer Science
Howie Choset discusses motion, snake robots, urban search and rescue, nuclear power plant inspection, minimally invasive surgical robotics and a rebirth of a new kind of efficient …

RI Seminar: Hadas Kress-Gazit : Formal Methods for Robotics in the Age of Big Data
https://www.ri.cmu.edu/event/formal-methods-for-robotics-in-the-age-of-big-data/ Hadas Kress-Gazit Geoffrey S.M. Hedrick Senior Endowed Professor Sibley School of Mechanical and Ae…

Intelligent Workcell Project Demo
Daniel Huber, of the Carnegie Mellon University Robotics Institute, explains the Intelligent Workcell Project during public tours in April 2015.…

Stanford Seminar - From open-source to safety-certified robotic software
January 27, 2023 Jan Becker of Apex.ai For decades, automotive and robotics developers have reinvented the software wheel many times. With its launch in 2010, ROS has enabled rapid…

RI Seminar: Henny Admoni: Toward Natural Interactions With Assistive Robots
Henny Admoni Assistant Professor, Robotics Institute at Carnegie Mellon University Abstract Robots can help people live better lives by assisting them with the complex tasks involv…

Stanford Seminar - Democratizing Robot Learning
Dr. Matthew Gombolay, Assistant Professor of Interactive Computing at the Georgia Institute of Technology November 18, 2022 New advances in robotics and autonomy offer a promise of…

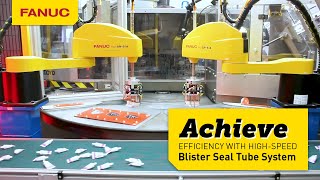
Achieve Efficiency with High-Speed Blister Seal Tube System
Remtec, a FANUC Authorized System Integrator, has developed a rotary blister seal retail pack machine. This system integrates FANUC Line Tracking, iRPickTool, and iRVision2D Guidan…


Lecture 01 for MIT 6.832 (Underactuated Robotics)
What is underactuated robotics? Motivation, definitions, and examples.…

RI Seminar : Matt Mason : A Manipulation Journey
Matthew T. Mason Professor Emeritus Robotics Institute, Carnegie Mellon University October 10, 2025 https://www.ri.cmu.edu/event/a-manipulation-journey/ Matt's Blog https://mtmason…

RI Seminar: Sebastian Scherer & Matthew Travers : Team Explorer’s Approach and Lessons Learned
https://www.ri.cmu.edu/event/sub-t-challenge/ Sebastian Scherer & Matthew Travers Robotics Institute, Carnegie Mellon University November 19, 2021 Resilient Exploration in SubT Env…

Episode 2: Join the Automation Generation with Lorain County Community College
Tackle the Skills Gap: Join the Automation Generation The skills gap has hit both large and small companies in every industry. It’s a growing challenge to find people to operate, m…

Lecture 6 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

RI Seminar: Jiaoyang Li : How to Coordinate Thousands of Robots
Jiaoyang Li Assistant Professor Robotics Institute, Carnegie Mellon University November 21, 2025 https://www.ri.cmu.edu/event/how-to-coordinate-thousands-of-robots-efficiently-and-…


Lecture 10 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

RI Seminar: Mac Schwager : Enabling Robots to Cooperate & Compete: Distributed Optimization...
https://www.ri.cmu.edu/event/ri-seminar-mac-schwager-stanford-university-assistant-professor-2021-02-12/ Enabling Robots to Cooperate & Compete: Distributed Optimization & Game The…

RI Seminar: Raj Madhavan : Humanitarian Robotics and Automation Technologies
Raj Madhavan Founder and CEO, Humanitarian RoboticsTechnologies, LLC April 22, 2016 Abstract Robotics and automation technologies hold immense promise in transforming people’s live…

RI Seminar: Herman Herman : Lesson Learned from Two Decades of Robotics Development
Herman Herman Director of the National Robotics Engineering Center Robotics Institute, Carnegie Mellon University Friday, September 14 Lesson Learned from Two Decades of Robotics D…

RI Seminar: Matthew Johnson-Roberson : Lessons from the Field
https://www.ri.cmu.edu/event/ri-seminar-matthew-johnson-roberson-cmu-2022-02-04/ Matthew Johnson-Roberson Professor / Director of RI Robotics Institute, Carnegie Mellon University …

WKW uses Robotic Laser Technology to Accelerate Production
WKW North America is a Tier 1 automotive supplier of aluminum anodized extrusions. They recently selected Shape Process Automation (SPA), a FANUC Authorized System Integrator, to d…
RI Seminar: David Fouhey : Understanding the Physical World from Images
David Fouhey Assistant Professor University of Michigan February 24, 2023 https://www.ri.cmu.edu/event/understanding-the-physical-world-from-images/ Understanding the Physical Worl…

RI Seminar: Yaser Ajmal Sheikh : Social Perception for Machines
Yaser Ajmal Sheikh Associate Professor Robotics Institute, Carnegie Mellon University February 1, 2019 Social Perception for Machines Abstract: Despite decades of progress, machine…

Lecture 7 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

Lecture 23: MIT 6.800/6.843 Robotics Manipulation (Fall 2021) | "Tactile sensing and course wrap-up"
https://slides.com/russtedrake/fall21-lec23…

Lecture 11 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…


Lecture 7: MIT 6.800/6.843 Robotics Manipulation (Fall 2021) | "Geometric Perception (Part 3)"
Slides available at: https://slides.com/russtedrake/fall21-lec07…

RI Seminar: Rebecca Taylor : DNA and gammaPNA in programmable nanomaterials...
Rebecca Taylor Assistant Professor Mechanical Engineering, Carnegie Mellon University DNA and gammaPNA in programmable nanomaterials for sensing, robotics and manufacturing https:/…

Isaac GR00T: NVIDIA Just Unveiled a Humanoid Robot Built for Research
NVIDIA is making humanoid robotics more accessible with the launch of the Isaac GR00T Reference Humanoid Robot. Designed as an open platform for researchers and developers, this sy…

Lecture 19 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

Oliver Kroemer discusses Saywer : IAM Lab : CMU Robotics Institute
The Intelligent Autonomous Manipulation (IAM) Lab at the Carnegie Mellon University (CMU) Robotics Institute brings together researchers to address the challenges of creating gener…


Carnegie Mellon opens robotics innovation center in Pittsburgh
Carnegie Mellon University celebrated the grand opening of its Robotics Innovation Center at Hazelwood Green, bringing together state and community leaders, students and scientists…

Stanford Seminar: Robotics in Our Everyday Lives: A Product Designer's Perspective
Carla Diana University of Pennsylvania Something exciting has been happening to our everyday objects. Things that were once silent and static can now sing, glow, buzz and be tracke…

RI Seminar: Erol Şahin : Augmenting Bee Colonies with Robotics and AI Tech...
Augmenting Bee Colonies with Robotics and AI Technologies for Ecosystem Support https://www.ri.cmu.edu/event/augmenting-bee-colonies-with-robotics-and-ai-technologies-for-ecosystem…

Lecture 14 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

RI Seminar: Sarah Bergbreiter : Microsystems-inspired robotics
Abstract and bio: https://www.ri.cmu.edu/event/ri-seminar-sarah-bergbreiter-carnegie-mellon-university-professor-2019-09-13/…

Lecture 19: MIT 6.800/6.843 Robotics Manipulation (Fall 2021) | "How to Train your Robot"
Guest Lecture by Abhishek Gupta. "How To Train Your Robot: Techniques for Establishing Robotic RL in the Real World"…

Robotics Institute Summer Scholars : 2014 : Talha Agcayazi & Christopher Eriksen
http://www.ri.cmu.edu/ri_static_content.html?menu_id=464…

Robotics Institute Summer Scholars : 2014 : Hesham Zaini
http://www.ri.cmu.edu/ri_static_content.html?menu_id=464…
Lecture 15 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

Interacting With and Through Personal Robots
(November 19, 2010) Leila Takayama of Willow Garage gives a presentation on the current state of robotic technology and where it could be headed in the future. She focuses on the w…

AI Robots Just Got More Insane… (XPeng, Figure 03 & Robot Cops)
Dozens of Figure 03 robots fill Figure AI’s headquarters, while DEEP Robotics humanoids assist traffic police at the Hangzhou Marathon. This robotics roundup follows four developme…

RI Seminar: Victoria Webster-Wood : Robots as Models for Biology and Biology for Robotics
Victoria Webster-Wood Robotics Institute Carnegie Mellon University February 20, 2026 https://www.ri.cmu.edu/event/robots-as-models-for-biology-and-biology-and-materials-for-robots…

How does Atlas learn? | Inside the Lab | Boston Dynamics
Just months after its debut, Atlas is proving why it is the world’s most capable and dynamic humanoid robot, ready for real work. Lifting a mini-fridge is a feat of strength, but t…

Lecture 13 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

MJC Engineering
MJC Engineering manufactures advanced CNC metal spinning equipment for customers throughout the world. The company received an order from a Japanese company to build a metal spinni…

Lecture 16 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…

Lecture 18 | MIT 6.832 (Underactuated Robotics), Spring 2018
For more about the course see the website: http://underactuated.csail.mit.edu/Spring2018…


Gemini Robotics 2: Google DeepMind’s Breakthrough in Whole-Body Robot Control
Google DeepMind just dropped Gemini Robotics 2 — its most advanced vision-language-action model yet. This isn’t just another robot brain. It’s a full system that turns what a robot…

ETH Zurich Robotics Summer Fellowship 2026 🇨🇭 | Fully Funded | Complete Process
This video covers the ETH Zurich Robotics Summer Fellowship 2026, a fully funded opportunity for students interested in robotics, AI, and engineering. In this video, you’ll get the…


Underactuated Robotics - MIT - 01
Lecture 01: Introduction Topics covered: Introduction Instructors: Russell Tedrake Source: OCW MIT - Massachusetts Institute of Technology More information is available in the play…
Homanga Bharadhwaj - Understanding and Predicting Human Behavior for Dexterous Manipulation
Homanga Bharadhwaj (Assistant Professor at Johns Hopkins University) gives the talk "Understanding and Predicting Human Behavior for Dexterous Manipulation" at the Mila Robot Learn…

U of T Robotics Institute Seminar: Aran Nayebi (CMU)
Using Embodied Agents to Reverse-Engineer Natural Intelligence Modern AI faces (at least!) two challenges: (1) building agents capable of autonomy and life-long learning, and (2) e…

CoRL 2026 Vlog: What I Learned About the Robot Data Market | Austin
CoRL 2026 in Austin: three days at the world's top robot learning conference, from Bangkok to LA to Austin, and what it all means for the robot data market. NVIDIA, Google DeepMind…


Robotic Digital Twins with FANUC + NVIDIA Isaac Sim
Now you can go beyond simulation and build a true digital twin factory to do full virtual commissioning. FANUC America CEO Mike Cicco talks about how they're now using NVIDIA AI in…

[IPPS2022 Keynote] Cyrill Stachniss - Robotics & Mobile Sensing Towards Sustainable Crop Production
Crop farming plays an essential role in our society, providing us food, feed, fiber, and fuel. We heavily rely on agricultural production but at the same time, we need to reduce th…

NVIDIA Isaac ROS 5.0 Brings AI Agents to Open-Source Robotics
🔹 NVIDIA released Isaac ROS 5.0 with new AI-agent workflows and expanded open-source Physical AI tools. 🔹 Its GPU-accelerated ROS packages help developers build robots that perceiv…

Stanford University Course Lecture 1 Introduction to Robotics
Course Description : Contents: Introduction to Robotics - Spatial Descriptions - Homogeneous Transform Interpretations - Manipulator Kinematics - Summary - Frame Attachment - Insta…

NVIDIA Isaac Lab 3.0 Can Train AI Robots at Scale!
🔗 ACCESS THE AI PROFIT BOARD ROOM https://sanny-recommends.com/learn-ai NVIDIA reports about 135,000 frames per second for Unitree H1 walking and more than 150,000 for a Franka arm…

Google DeepMind's New Robot AI Just Went to Work at Mercedes
A humanoid robot just did real work on a live Mercedes-Benz production line. Google DeepMind's Gemini Robotics 2.5 — its most capable vision-language-action (VLA) model yet — power…

2025-02-11 History and Overview of CMU's Robotics Institute
On February 11, 2025, the Squirrel Hill Historical Society presented "Our Futuristic Murray Avenue Neighbor: An Overview of CMU’s Robotics Institute," or as it was titled by the pr…

Underactuated Robotics - MIT - 10
Lecture 10: Trajectory Stabilization and Iterative Linear Quadratic Regulator Topics covered: Trajectory stabilization and iterative linear quadratic regulator (iLQR) Instructors: …

Resurrecting Model-Based Control and Learning | Emo Todorov | CoRL 2026 Invited Talk
Resurrecting Model-Based Control and Learning Invited talk by Emo Todorov, University of Washington and Roboti. CoRL 2026 workshop: Open Problems in Contact-Rich Loco-Manipulation …
Underactuated Robotics - MIT - 23
Lecture 23: Case Studies in Computational Underactuated Control Topics covered: Case studies in computational underactuated control Instructors: Russell Tedrake Source: OCW MIT - M…

How ETH Zurich Teaches Robots to Walk in 4 Minutes
Humanoid robots don't learn to walk in the real world first. They learn in simulation, falling over again and again, then transfer what they learned to real hardware. Here's how it…
Advancing Robot Intelligence Lecture 17 at Stanford Deep Reinforcement Learning Course at Stanford
We explore the cutting edge of Advancing Robot Intelligence, specifically focusing on the transition from successful simulation-based training to real-world deployment and the purs…
Contacts and Dynamics for Manipulation & Locomotion | Pulkit Agrawal | CoRL 2026 Invited Talk
Contacts and Dynamics for Manipulation & Locomotion Invited talk by Pulkit Agrawal, MIT. CoRL 2026 workshop: Open Problems in Contact-Rich Loco-Manipulation November 12, 2026 · Aus…

Underactuated Robotics - MIT - 22
Lecture 22: Actor-critic Methods Topics covered: Actor-critic methods Instructors: Russell Tedrake Source: OCW MIT - Massachusetts Institute of Technology More information is avail…

Underactuated Robotics - MIT - 16
Lecture 16: Introducing Stochastic Optimal Control Topics covered: Introducing stochastic optimal control Instructors: Russell Tedrake Source: OCW MIT - Massachusetts Institute of …
Underactuated Robotics - MIT - 21
Lecture 21: Policy Improvement Topics covered: Policy improvement Instructors: Russell Tedrake Source: OCW MIT - Massachusetts Institute of Technology More information is available…